Lauritz Knudsen
Lauritz Knudsen xD4000 AC Drive – Specs & Programming Guide
xD4000 Series AC Drives: Complete Guide to Features, Specifications & Programming
⚡ The xD4000 is the flagship of Lauritz Knudsen Electrical & Automation’s AC drive lineup — a highly advanced VFD built for manufacturing, water treatment and process automation, with the widest power range (0.37kW Heavy Duty to 315kW Normal Duty), the richest fieldbus and accessory ecosystem, and application functions found nowhere else in the Lauritz Knudsen range: Master-Slave speed and torque control over onboard Ethernet, dedicated crane and hoist functions, closed-loop vector control with encoder feedback, and oil & gas-specific pump functions. This guide covers everything from decoding the model number to wiring the drive and commissioning it for your application.
💡 Main Features
✅ Advanced Graphical LCD keypad built in (detachable, mountable on a panel door with an accessory kit) — 8-line, IP65, 2-colour backlight (red for a fault, white for normal running), with bar charts, gauges and trend displays, 24 selectable languages (expandable), an embedded dynamic QR code for contextual help, and copy/paste configuration both drive-to-drive and PC-to-drive (up to 16 stored configurations)
✅ Inbuilt battery powers the real-time clock, data acquisition and time-stamping when the drive is stopped, and keeps a fault history with real timestamps — rated for a 10-year service life
✅ Inbuilt DC reactor across the entire range (around 40% impedance at rated load, ~48% at 80% load) — supports motor cable runs up to 300m without an output filter, and up to 1000m with a dV/dt or sinus filter depending on cable length and whether the motor conforms to IEC 60034-25
✅ Inbuilt EMC filter across the entire range — Category C2 per IEC 61800-3 up to 45kW, Category C3 above that, and compliant with Category C1 when an external EMC filter is added
✅ External 24VDC connection for when 3-phase supply isn’t present — keeps the display, control circuitry and fieldbus communication alive, and lets you monitor I/O status and control digital inputs/outputs
✅ Full control method range: V/F and Advanced Vector Control with and without encoder feedback for induction motors, plus dedicated control methods for permanent magnet and reluctance motors — the only series in the Lauritz Knudsen range with closed-loop current (full-flux) vector control
✅ Torque boost, mains and output contactor control, slip compensation, 16 preset speeds, automatic restart, cooling fan control, fast stop ramp divider, and IGBT self-test on power-up and before every RUN command (checking for an output short-circuit, an inoperable IGBT, or a short-circuited IGBT)
✅ Acceleration/deceleration profiles: linear, S-curve, U-curve or a customised S-curve, with reference addition, subtraction and multiplication, plus delinearization for analog inputs
🏗️ Application-Specific Functions (Master-Slave, Crane, Oil & Gas, Pumps)
The xD4000 is the only Lauritz Knudsen series with dedicated multi-drive coordination and crane/hoist control built in, alongside the pump and oil & gas functions shared with smaller series. Here’s the full breakdown:
Master-Slave & MultiDriveLink (multi-drive coordination over Ethernet)
✅ Master-Slave with onboard Ethernet port — one master drive can synchronise up to 10 slave drives over Ethernet, in either Speed or Torque master-slave mode, for common-shaft or load-sharing applications: a dual-motor kiln in a DRI plant, tandem crane/grab crane operation, long belt conveyors, or parallel chains in stenter/textile machines
✅ MultiDriveLink — a torque-sharing mode for two or more motors with directly-coupled shafts: the slave adjusts its output to match the torque difference against the master, balancing the load digitally over an Ethernet link rather than analog tuning. Supports Daisy Chain, Star, or Redundant Ring (with an RSTP switch) topologies, giving easier standard Ethernet cabling, more precise digital torque management, and automatic load equilibrium without complex analog tuning
Crane & hoist functions
✅ Built-in braking transistor up to 160kW HD, with brake control and brake feedback, high-speed hoisting, rope slack detection, external weight measurement, and dynamic load detection
✅ Brake control adapted for horizontal and vertical movement — separately configurable Brake Release (current, time, frequency) and Brake Engage (frequency, delay, time) parameters for vertical movement (crane/hoist) and horizontal movement (long travel/cross travel), plus interlocks for brake feedback, brake contactor feedback, brake restart sequence, and load-slip monitoring in closed loop, with separate brake-release current settings for hoisting vs. lowering (forward and reverse)
✅ High-speed hoisting — adapts motor speed to the load: below nominal load, hoisting speed can exceed the motor’s nominal speed (e.g. a faster-travelling empty crane hook on lower and raise)
✅ Rope slack detection — prevents a high-speed start when the load is on the ground and the rope is slack, avoiding uneven cable winding on the drum and rope/jib-crane stress when the cable suddenly goes taut
✅ External load measurement via a weight sensor — adapts the Brake Release Current to the actual load weight (heavier load, higher release current; lighter load, lower), reducing start jerk on small loads
✅ Dynamic load detection — works alongside high-speed hoisting to detect an obstacle via a sudden load change, in either Speed Reference mode (faults if current exceeds an initial-speed comparison) or Current Limitation mode (faults if frequency drops below a set limit as load increases)
✅ Torque limitation & torque control — limits motor torque generally, e.g. a gate-barrier VFD that limits torque so the barrier doesn’t damage a car underneath it, or winding/unwinding applications where speed automatically decreases as drum diameter increases
✅ Positioning by limit switches or sensors — manages positioning via digital-input-linked position sensors or limit switches, with two configurable commands (Stopping, Slowing Down) and a configurable stop mode; once a stop contact activates, only movement in the opposite direction is authorised
Oil & gas functions
✅ ENA (Energy Adaptation) / Sucker Rod function — a control profile for rotating machines with unbalanced load, such as oil pumps. During deceleration the motor generates power back into the VFD (an overvoltage risk without a braking resistor); ENA allows braking-resistor-free operation, reduces mechanical stress on the rod, reduces line current fluctuation, and cuts energy consumption
✅ Backspin control for PCP (Progressive Cavity Pump) — if the motor freewheels during a mains fault with fluid still in the column, the fluid flows back and spins the pump in reverse; the backspin function uses this regenerative energy to control the backspin speed, and on power return the motor moves forward again to resume production
Pump-specific features
✅ Built-in PID with 4 preset references selectable via digital inputs, Wake-Up & Sleep mode with Sleep Boost, and PID Predictive Speed (pre-PID frequency)
✅ Feedback (pipe break/end-of-curve) monitoring — detects a fire hydrant opening, pump start-up against an open discharge valve, a mechanical pipe breakdown, or water leakage
✅ Pump cycle monitoring — tracks the number of starts to avoid unwanted ageing
✅ ENA (Energy Adaptation) and Backspin Control for PCP pumps, as above
Further application-specific functions
✅ Load sharing — for two mechanically-linked motors each on its own drive: if Motor-1 is more loaded than Motor-2, Motor-1 slows and Motor-2’s load increases automatically, improving torque distribution (a DRI kiln, a tandem crane, a radar, or a long conveyor belt)
✅ Backlash sequence — regulates start-up speed under torque limitation until backlash is fully compensated, after which load torque exceeds the limitation and stops the movement, reducing gear wear and maintenance downtime
✅ Motor surge limit (for old or rewound motors), motor/generator torque limit, Power Backup Mode (temporary VFD operation during a power outage), Kinetic Energy Buffering (maintains DC bus voltage), motor thermal monitoring via PTC/PT100/PT1000/KTY84 probes
✅ Sleep/Wake-Up in speed control mode, stall prevention (deceleration ramp adaptation plus running current limit), Skip (Jump) Frequency, Catch-on-the-Fly (speed search/flying start), Fault inhibition and error-detect disabling (Fire Mode), DC braking during stopping, and Multiconfiguration Mode
📋 Understanding the xD4000 Model Number
Every xD4000 drive’s part number follows the format xD4000-1234-VIBDEF. Here’s how each position decodes:
| Code Position | Meaning |
|---|---|
| xD | Product — xD = Drives |
| 4000 | Drive model number |
| 1234 | Current rating code (A) — e.g. 02P2 = 2.2A, 46P3 = 46.3A, 616P = 616A |
| V — Mains Voltage | 4 = 3-Phase 380–480VAC (the only mains-voltage class this series is offered in) |
| I — IP Class | A = IP00 · B = IP20 · C = IP21 — the only Lauritz Knudsen series offered across three IP classes, tracking frame size (IP21 up to 90kW ND, IP20 from 110–160kW ND, IP00 from 220–315kW ND) |
| B — Braking Unit | 2 = With Braking Unit · 1 = Without Braking Unit — unlike the xD2000, this series does offer a braking unit (built-in up to 250kW ND; external DBU-200K-100 required on the two largest ratings, 250kW HD/315kW ND and 200kW HD/250kW HD) |
| D — DC Reactor | 2 = With DC reactor (built into every rating in this series) |
| E — EMC Filter | 2 = With EMC filter (built into every model in this series) |
| F — Future Use | 1 = Reserved |
💡 For example, XD4000-46P3-4C2221 is a 46.3A, 3-phase 380–480VAC drive, IP21, with a built-in braking unit, a built-in DC reactor, and a built-in EMC filter. Compare that with XD4000-481P-4A1221 at the top of the range: 481A, IP00, and “1” for the Braking Unit digit — this rating needs the external XDBU-200K-100 Dynamic Braking Unit rather than a built-in one.
🌐 Network Architecture
The xD4000 has the richest fieldbus support of any Lauritz Knudsen series, with five documented network topologies straight from the catalog. Over the built-in Modbus RTU serial link, a PLC connects through a Modbus splitter to a daisy chain of xD4000 drives via Modbus T-junctions, with line terminators fitted at the ends of the chain. Over built-in Ethernet IP, a PLC connects directly to a daisy chain of drives, with an optional web browser client also able to join the same network for monitoring. With the optional XDCI-CND-V01 CANopen card, drives are wired in a daisy-chain CANopen bus back to the PLC; with the XDCI-CNS-V01 card instead, the same bus is wired in a Sub-D star-style topology. With an optional Profinet card, drives can be arranged in a daisy or star network through a dedicated Profinet switch. And for installations that need high reliability, the drives can be wired in an RSTP Ethernet Network — a redundant ring topology using two RSTP Ethernet switches, so a single cable break doesn’t take the network down.
⚖️ Available Models & Ratings
The xD4000 is dual-rated: Normal Duty (ND, 120% overload for 60s) suits light, variable-torque loads at a higher continuous kW, while Heavy Duty (HD, 150% overload for 60s) suits harder-starting, constant-torque loads at a lower continuous kW on the same drive. All ratings below are 3-phase, 380–480VAC.
| Model No. | Power ND (kW) | Current ND (A) | Power HD (kW) | Current HD (A) | Apparent Power ND (kVA) | Apparent Power HD (kVA) | Input Current ND at 480V (A) | Input Current HD at 480V (A) |
|---|---|---|---|---|---|---|---|---|
| XD4000-02P2-4C2221 | 0.75 | 2.2 | 0.37 | 1.5 | 1.1 | 0.7 | 1.3 | 0.8 |
| XD4000-04P0-4C2221 | 1.5 | 4.0 | 0.75 | 2.2 | 2.2 | 1.2 | 2.6 | 1.5 |
| XD4000-05P6-4C2221 | 2.2 | 5.6 | 1.5 | 4.0 | 3.2 | 2.4 | 3.8 | 2.9 |
| XD4000-07P2-4C2221 | 3.0 | 7.2 | 2.2 | 5.6 | 4.2 | 3.3 | 4.5 | 4.0 |
| XD4000-09P3-4C2221 | 4.0 | 9.3 | 3.0 | 7.2 | 5.6 | 4.5 | 6.0 | 5.4 |
| XD4000-12P7-4C2221 | 5.5 | 12.7 | 4.0 | 9.3 | 7.6 | 6.0 | 8.0 | 7.2 |
| XD4000-16P5-4C2221 | 7.5 | 16.5 | 5.5 | 12.7 | 9.9 | 7.6 | 10.5 | 9.2 |
| XD4000-23P5-4C2221 | 11 | 23.5 | 7.5 | 16.5 | 14.1 | 10.4 | 17.0 | 12.5 |
| XD4000-31P7-4C2221 | 15 | 31.7 | 11 | 23.5 | 19.4 | 15.0 | 23.3 | 18.1 |
| XD4000-39P2-4C2221 | 18.5 | 39.2 | 15 | 31.7 | 24.0 | 20.3 | 28.9 | 24.4 |
| XD4000-46P3-4C2221 | 22 | 46.3 | 18.5 | 39.2 | 28.6 | 24.9 | 34.4 | 29.9 |
| XD4000-61P5-4C2221 | 30 | 61.5 | 22 | 46.3 | 38.2 | 29.8 | 45.9 | 35.8 |
| XD4000-74P5-4C2221 | 37 | 74.5 | 30 | 61.5 | 47.6 | 40.2 | 57.3 | 48.3 |
| XD4000-88P0-4C2221 | 45 | 88.0 | 37 | 74.5 | 57.4 | 49.1 | 69.1 | 59.0 |
| XD4000-106P-4C2221 | 55 | 106.0 | 45 | 88.0 | 70.0 | 59.7 | 84.2 | 71.8 |
| XD4000-145P-4C2221 | 75 | 145.0 | 55 | 106.0 | 93.7 | 72.2 | 112.7 | 86.9 |
| XD4000-173P-4C2221 | 90 | 173.0 | 75 | 145.0 | 112.9 | 98.2 | 135.8 | 118.1 |
| XD4000-211P-4B2221 | 110 | 211.0 | 90 | 173.0 | 121.8 | 102.6 | 165.0 | 143.0 |
| XD4000-250P-4B2221 | 132 | 250.0 | 110 | 211.0 | 161.4 | 121.8 | 213.0 | 165.0 |
| XD4000-302P-4B2221 | 160 | 302.0 | 132 | 250.0 | 201.3 | 161.4 | 262.0 | 213.0 |
| XD4000-427P-4A2221 | 220 | 427.0 | 160 | 302.0 | 247.0 | 187.0 | 324.0 | 246.0 |
| XD4000-481P-4A1221 | 250 | 481.0 | 200 | 387.0 | 279.0 | 229.0 | 366.0 | 301.0 |
| XD4000-616P-4A1221 | 315 | 616.0 | 250 | 481.0 | 351.0 | 286.0 | 461.0 | 375.0 |
💡 This is the widest power range and the largest model count of any Lauritz Knudsen series covered so far — 23 models spanning 0.37kW HD up to 315kW ND, all in a single 380–480VAC voltage class, across seven distinct frame sizes.
🔧 Technical Specifications
| Power range | 0.37 – 250 kW (Heavy Duty) · 0.75 – 315 kW (Normal Duty) |
| Enclosure type | IP21 up to 90kW (ND) · IP20 from 110–160kW (ND) · IP00 from 220–315kW (ND) — the only Lauritz Knudsen series spanning three IP classes |
| Isolation type | Galvanic isolation |
| Rated voltage | 3-Phase 380–480VAC (-15/+10%) |
| Rated frequency | 50/60Hz (±5%) |
| Max output voltage | Proportional to input voltage |
| Max output frequency | 0.1–599Hz — the widest range of any Lauritz Knudsen series covered |
| Overload capacity | Heavy Duty: 150% of rated current for 1 min · Normal Duty: 120% for 1 min |
| Control method | Open Loop — Asynchronous motor: V/F 5-point, Slip Compensation, Energy Saving, Sensorless Vector Control (SVC V); Synchronous motor: PM motor control law, PM control law for variable torque; Reluctance motor: reluctance motor control law. Closed Loop — Asynchronous motor: Current (Full Flux) vector control law; Synchronous motor: PM motor control law |
| V/F patterns | Linear, S Ramp, U Ramp, Customized (S-curve) |
| Acceleration / deceleration time | 0.0s – 6000s |
| Starting torque | 150% at 3Hz in V/F |
| Transient overtorque | Up to 180% of nominal motor torque, depending on drive rating and motor type |
| Braking torque | Up to 150% of nominal motor torque with DBR · around 20% on average at low speed without DBR |
| Efficiency at full load | 94.9 – 98.6% |
| Power factor | Displacement ≈ 0.99 · True PF ≈ 0.90 |
| %THDi | 38 – 47% |
| Built-in keypad | Advanced Graphical LCD, IP65, connected via RJ45, 8-line, 2-colour backlight, 24 languages, bar charts/gauges/trends, inbuilt battery, QR-code help |
| EMC filter | Built-in across the entire range — Category C2 (IEC 61800-3) up to 45kW, Category C3 above 45kW; complies with Category C1 with an external EMC filter added |
| DC reactor | Built-in across the entire range (~40% impedance at rated load, ~48% at 80% load) — supports motor cable runs up to 300m without an output filter, up to 1000m with a dV/dt or sinus filter depending on cable length and IEC 60034-25 conformance |
| Motor protection | Motor overload, overcurrent, short-circuit, ground short-circuit, e-thermal protection (motor thermal monitor), 1-Ph and 3-Ph output phase loss (no motor detection) |
| Drive protection | Precharge-circuit error, IGBT short-circuit, autotuning fault, drive overheating, overvoltage, undervoltage, input phase loss, load short-circuit, fieldbus interruption, HMI communication fault, IGBT overheat |
| Process protection | Motor overspeed, process overload, process underload, AI 4–20mA current loss, load slipping, brake control/feedback fault, safety fault, speed feedback loss (pulse or encoder) |
| Interface | 8 digital inputs, 2 pulse inputs (DI7/DI8, 0–30kHz), 1 sensor (PTC) input (DI6), 3 analog inputs (2×0–10Vdc/0–20mA + 1×−10 to +10Vdc, 12-bit), 2 safety inputs, 4 digital outputs (3 relay + 1 logic), 1 pulse output (0–30kHz), 2 analog outputs (0–10Vdc/0–20mA, 10-bit) |
| Ambient temperature (operation) | Frames S1–S6: −15°C to +50°C without derating, up to +60°C with derating · Frame S7: −10°C to +40°C without derating, up to +60°C with derating |
| Cooling | Forced fan cooling structure across the entire range |
| Communication protocol | Built-in Modbus, Modbus TCP or Ethernet IP (1 RJ45 for Modbus + 2 RJ45 for Modbus TCP/Ethernet IP), 4800–38400bps for Modbus, 10/100Mbps for Ethernet · Optional fieldbus cards for PROFIBUS (Sub-D), PROFINET (dual-port RJ45, with an S2-redundancy variant), DeviceNet (5-pin open style) and CANopen (dual-port RJ45, Sub-D, and 5-pin open-style variants) |
| Compliance | CE, RoHS · IEC 61800-3, IEC 61800-5-1, IEC 60721-3 |
🔌 Wiring the xD4000 Drive
The xD4000 has three wiring zones: the main power circuit, the motor output, and the control terminal block, plus a dedicated Safe Torque Off (STO) input pair.
Main power & motor circuit
✅ R/L1, S/L2, T/L3 — 3-phase 380–480V mains supply, switched through an upstream contactor (KM1)
✅ U/T1, V/T2, W/T3 — output to the motor
✅ A common protection pattern from the catalog: relay output R1A/R1C is wired to hold in contactor KM1 (via KM1’s own auxiliary contact, A1/A2), so the supply is automatically switched off the moment the drive drops that relay on a fault
✅ Earth (⎓) — ground terminal, all ratings
Control terminals
| Terminal | Type | Function |
|---|---|---|
| DI1–DI8 | Logic input | 8 programmable digital inputs (sink/source), 24Vdc (30Vdc max), impedance 3.5kΩ — DI6 doubles as the PTC sensor input, DI7/DI8 double as pulse inputs (0–30kHz) |
| 10V, AI1, COM | Analog input | Reference potentiometer input, 0–10Vdc / 0–20mA, 12-bit resolution |
| AI2, AI3 | Analog input | −10 to +10Vdc / 0–20mA, configurable as a temperature probe or water-level sensor input |
| AQ1, AQ2 | Analog output | 0–10Vdc / 0–20mA output, 10-bit resolution — e.g. for a remote frequency or process meter |
| R1A/R1B/R1C | Relay output | Form C changeover relay contact — commonly wired to hold in the mains contactor |
| R2A/R2C, R3A/R3C | Relay output | Form A relay contacts, plus 1 additional logic output and 1 transistor output |
| STOA, STOB | Safety input | 2 Safe Torque Off inputs, +24Vdc (30Vdc max), impedance 2.2kΩ |
| P24, 0V | Power/reference | Onboard 24V supply rail and common, also used as the external 24VDC input point when 3-phase supply isn’t present |
⚠️ Always wire and check connections with the drive fully powered down and the DC bus capacitors discharged. Keep control wiring separate from the motor power cable. The built-in DC reactor and EMC filter (entire range) between them allow motor cable runs up to 300m without an output filter, and up to 1000m with a dV/dt or sinus filter depending on cable length and whether the motor conforms to IEC 60034-25 — check the exact filter requirement for your run length against the catalog before committing to an unusually long cable.
💻 Programming & Commissioning the xD4000 Drive
The xD4000 ships with its Advanced Graphical LCD keypad built in, and can be extended with encoder feedback, additional I/O, or any of eight optional fieldbus protocols for PLC-based control.
Keypad, encoder & I/O options
✅ XDOP-DOP-500 — the built-in IP65 Advanced Graphical LCD keypad, with XDKT-DOP-500 as its remote panel-door mounting kit
✅ XDIO-EX1-V01 — I/O Expansion Card-1 (6 digital inputs, 2 digital outputs, 2 analog inputs) and XDIO-EX2-V01 — I/O Expansion Card-2 (3 relay outputs)
✅ Encoder/resolver feedback cards — XDEN-DEI-V01 (Digital Encoder Interface), XDEN-AEI-V01 (Analog Encoder Interface Module), XDEN-REI-V01 (Resolver Interface Module) and XDEN-HEI-V01 (HTL Encoder Interface Module), needed for the closed-loop vector control modes this series supports
✅ XDSI-SIM-V01 — Additional Safety Integrity Module, alongside the two built-in STO safety inputs
Commissioning workflow
💡 Typical first-run sequence: power up the drive → enter the motor’s nameplate data (rated voltage, current, frequency and poles) → select the control mode that fits your load and motor type (V/F or Advanced Vector Control for induction motors, PM motor control law for permanent magnet motors, or one of the closed-loop modes if an encoder/resolver card is fitted) → set the acceleration/deceleration ramp shape and time (linear, S-curve, U-curve or customized, 0.0–6000s) → assign the 8 digital and 3 analog inputs to match your wiring, keeping in mind DI6 doubles as the PTC input and DI7/DI8 as pulse inputs → for crane/hoist installations, configure brake release/engage current, time and frequency separately for hoisting and lowering, plus rope slack and high-speed hoisting thresholds → for multi-drive installations, wire the Ethernet Master-Slave link (Speed or Torque mode, up to 10 slaves) or MultiDriveLink (Daisy Chain, Star, or Redundant Ring) and set which drive is master → for pump/oil & gas applications, configure the built-in PID (4 preset references, Wake-Up/Sleep with Sleep Boost) or the ENA/Backspin functions as needed → run the IGBT self-test before your first RUN command to confirm the output stage is healthy.
Communication setup
✅ Built-in Modbus, Modbus TCP or Ethernet IP — 1 RJ45 port for Modbus (2-wire RS485, 4800–38400bps) plus 2 RJ45 ports for Modbus TCP/Ethernet IP (10/100Mbps)
✅ Optional cards for PROFIBUS (XDCI-PDP-V01, Sub-D connector), PROFINET (XDCI-PFN-V01 dual-port RJ45, or XDCI-PFN-V02 with S2 redundancy), DeviceNet (XDCI-DEN-V01, 5-pin open style), EtherCAT (XDCI-ECT-V01), POWERLINK (XDCI-PLN-V01), and three CANopen variants — XDCI-CND-V01 (daisy chain), XDCI-CNS-V01 (Sub-D star) and XDCI-CNT-V01 (terminals) — the broadest fieldbus card selection of any Lauritz Knudsen series
🧩 Accessories
| CAT No. | Description |
|---|---|
| XDOP-DOP-500 | IP65 LCD Graphical Keypad |
| XDKT-DOP-500 | Mounting Kit for IP65 LCD Keypad |
| XDIO-EX1-V01 | I/O Expansion Card-1 — 6 Digital Inputs, 2 Digital Outputs, 2 Analog Inputs |
| XDIO-EX2-V01 | I/O Expansion Card-2 — 3 Relay Outputs |
| XDEN-DEI-V01 | Digital Encoder Interface Card |
| XDEN-AEI-V01 | Analog Encoder Interface Module |
| XDEN-REI-V01 | Resolver Interface Module |
| XDEN-HEI-V01 | HTL Encoder Interface Module |
| XDCI-ECT-V01 | EtherCAT Comm. Card |
| XDCI-PDP-V01 | Profibus-DP Comm. Card |
| XDCI-DEN-V01 | DeviceNet Comm. Card |
| XDCI-PLN-V01 | POWERLINK Comm. Card |
| XDCI-PFN-V01 | ProfiNet Comm. Card |
| XDCI-PFN-V02 | ProfiNet Comm. Card — Redundant |
| XDCI-CND-V01 | CANopen DaisyChain Comm. Card |
| XDCI-CNS-V01 | CANopen SUB-D Comm. Card |
| XDCI-CNT-V01 | CANopen Terminals Comm. Card |
| XDSI-SIM-V01 | Additional Safety Integrity Module |
| XDBU-200K-100 | Dynamic Braking Unit — 200kW (external, for the two largest ratings) |
🏭 Typical Applications
✅ Crushers — primary and secondary jaw crushers, cone crushers, VSI crushers
✅ Material handling — bucket elevators, vertical reciprocating conveyors, automated storage & retrieval systems
✅ Sponge iron / DRI plant equipment — kiln and cooler drives, ID/shell air fans, ABC fan, bag filter fan, lobe compressor, RW/HW/CW pumps
✅ Cranes & hoists — using the built-in braking transistor, brake control, rope slack detection and high-speed hoisting
✅ OEM textile machinery — air/draw texturizing machines, weaving machines, stenter machines, using Master-Slave and MultiDriveLink for synchronized multi-motor lines
✅ Oil & gas — sucker rod pumps (via ENA) and progressive cavity pumps (via Backspin Control)
✅ Water treatment & pumping stations — using built-in PID, pipe-break/end-of-curve feedback monitoring, and pump cycle monitoring
✅ Installations needing high-reliability networking — via the RSTP redundant-ring Ethernet topology
❓ Frequently Asked Questions
Does the xD4000 have a braking unit?
✅ Yes — unlike the xD2000, the xD4000 does offer a braking unit, built in for most ratings up to 250kW HD/315kW ND. The two largest ratings (200kW HD/250kW ND and 250kW HD/315kW ND) need the external XDBU-200K-100 Dynamic Braking Unit instead. You can check which applies to a given model from the Braking Unit digit in the part number (2 = built-in, 1 = needs the external unit).
What makes the xD4000 different from the xD1000, xD2000 and xD3000?
✅ It’s the widest-range and most advanced series in the lineup: the only one with Master-Slave/MultiDriveLink multi-drive coordination over Ethernet, dedicated crane and hoist control (brake control, rope slack detection, high-speed hoisting, dynamic load detection), closed-loop vector control with encoder feedback, three IP enclosure classes, and the broadest fieldbus card selection (eight optional protocol families plus three built-in options). If your application is a fan, pump or compressor without these needs, the xD1000 or xD2000 will likely be a simpler, more cost-effective fit.
Can I synchronise multiple xD4000 drives together?
✅ Yes, two ways. Master-Slave over the onboard Ethernet port synchronises speed or torque across up to 10 slave drives from one master — useful for common-shaft or load-sharing applications like a dual-motor kiln or a tandem crane. MultiDriveLink is a dedicated torque-sharing mode for motors with directly-coupled shafts, using Daisy Chain, Star or Redundant Ring topologies for more precise digital load balancing than analog tuning.
How long a motor cable can I run from an xD4000?
✅ Thanks to the built-in DC reactor and EMC filter (entire range), the xD4000 supports motor cable runs up to 300m without any additional output filter. Longer runs, up to 1000m, are supported with a dV/dt or sinus filter, depending on the exact cable length and whether the motor conforms to IEC 60034-25 — check the filter table for your specific run before committing to an unusually long cable.
Which communication protocols does the xD4000 support?
✅ Built-in Modbus, Modbus TCP and Ethernet IP on every model, plus optional cards for PROFIBUS, PROFINET (with a redundant variant), DeviceNet, EtherCAT, POWERLINK, and three CANopen variants (daisy chain, Sub-D star, and terminals). This is the broadest fieldbus support of any Lauritz Knudsen series covered — more than the xD1000 (Modbus only), xD2000 (Modbus + Profibus DP) or xD3000 (Modbus + CANopen + Ethernet + Profibus).
Does the xD4000 support closed-loop control with an encoder?
✅ Yes — with one of the optional encoder/resolver interface cards fitted (XDEN-DEI-V01 digital, XDEN-AEI-V01 analog, XDEN-REI-V01 resolver, or XDEN-HEI-V01 HTL encoder), the xD4000 runs closed-loop current (full-flux) vector control for induction motors, or closed-loop PM motor control for permanent magnet motors. This is the only series in the Lauritz Knudsen lineup covered here with full closed-loop vector control with encoder feedback.
🛒 Shop the xD4000 Series
🚀 All 23 models are in stock and ready to ship:
XD4000-02P2-4C2221 — 0.37kW HD / 0.75kW ND
XD4000-04P0-4C2221 — 0.75kW HD / 1.5kW ND
XD4000-05P6-4C2221 — 1.5kW HD / 2.2kW ND
XD4000-07P2-4C2221 — 2.2kW HD / 3kW ND
XD4000-09P3-4C2221 — 3kW HD / 4kW ND
XD4000-12P7-4C2221 — 4kW HD / 5.5kW ND
XD4000-16P5-4C2221 — 5.5kW HD / 7.5kW ND
XD4000-23P5-4C2221 — 7.5kW HD / 11kW ND
XD4000-31P7-4C2221 — 11kW HD / 15kW ND
XD4000-39P2-4C2221 — 15kW HD / 18.5kW ND
XD4000-46P3-4C2221 — 18.5kW HD / 22kW ND
XD4000-61P5-4C2221 — 22kW HD / 30kW ND
XD4000-74P5-4C2221 — 30kW HD / 37kW ND
XD4000-88P0-4C2221 — 37kW HD / 45kW ND
XD4000-106P-4C2221 — 45kW HD / 55kW ND
XD4000-145P-4C2221 — 55kW HD / 75kW ND
XD4000-173P-4C2221 — 75kW HD / 90kW ND
XD4000-211P-4B2221 — 90kW HD / 110kW ND
XD4000-250P-4B2221 — 110kW HD / 132kW ND
XD4000-302P-4B2221 — 132kW HD / 160kW ND
XD4000-427P-4A2221 — 160kW HD / 220kW ND
XD4000-481P-4A1221 — 200kW HD / 250kW ND
XD4000-616P-4A1221 — 250kW HD / 315kW ND
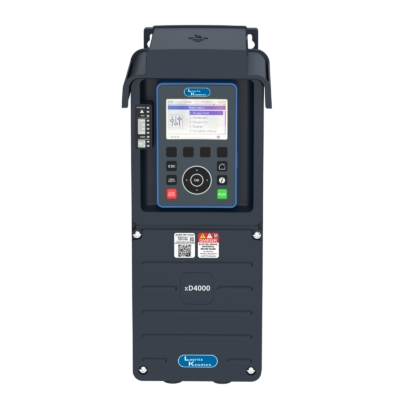
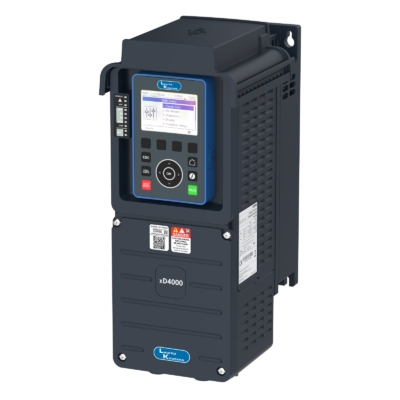
Lauritz Knudsen Electrical and Automation
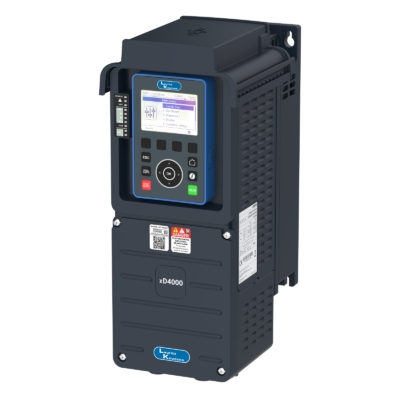
XD4000 0.37kW(HD)/0.75kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
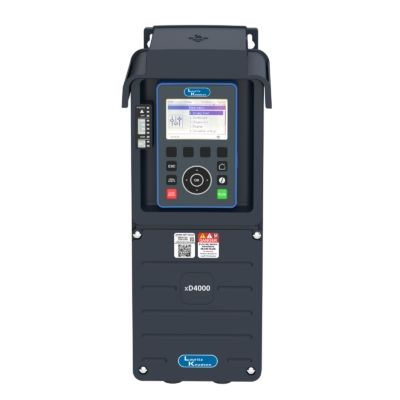
Lauritz Knudsen Electrical and Automation
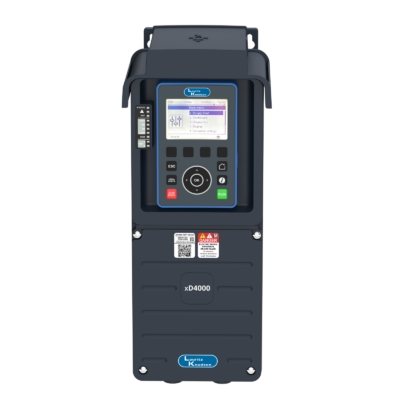
XD4000 0.75kW(HD)/1.5kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
Lauritz Knudsen Electrical and Automation
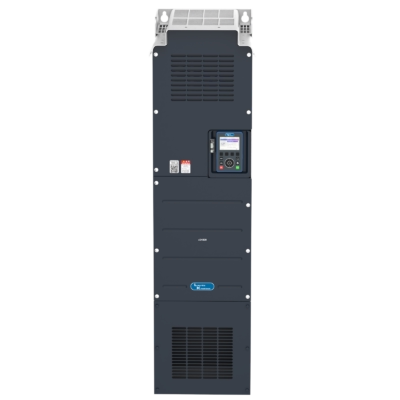
XD4000 1.5kW(HD)/2.2kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
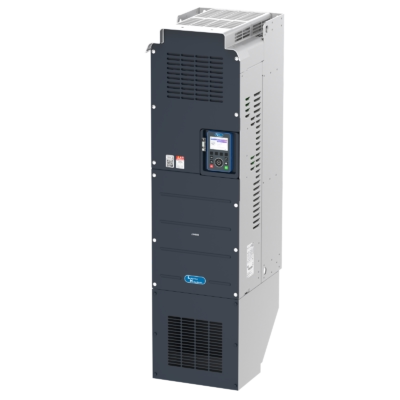
Lauritz Knudsen Electrical and Automation
XD4000 110kW(HD)/132kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
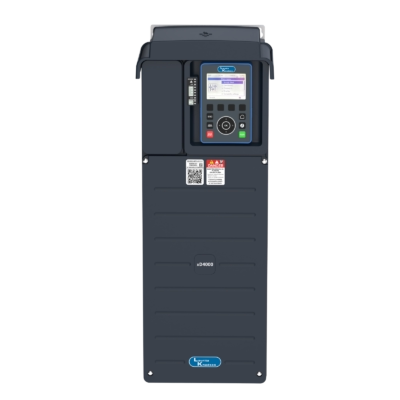
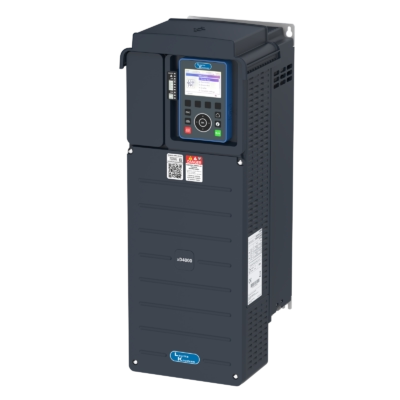
Lauritz Knudsen Electrical and Automation
XD4000 11kW(HD)/15kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
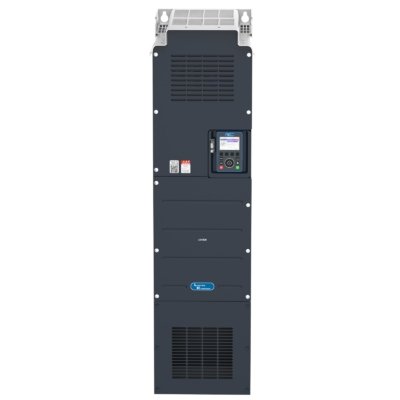
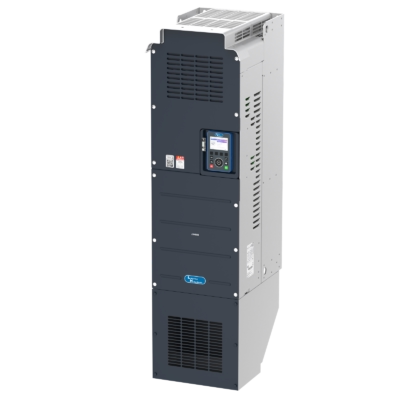
Lauritz Knudsen Electrical and Automation
XD4000 132kW(HD)/160kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
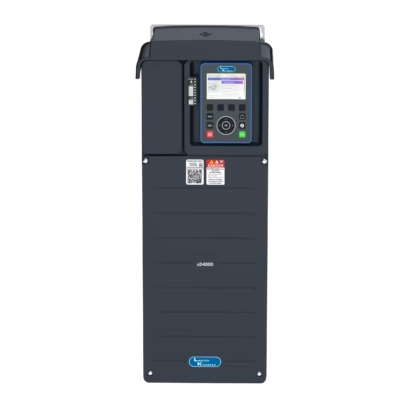
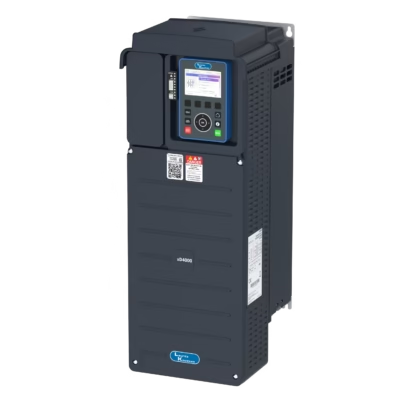
Lauritz Knudsen Electrical and Automation
XD4000 15kW(HD)/18.5kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
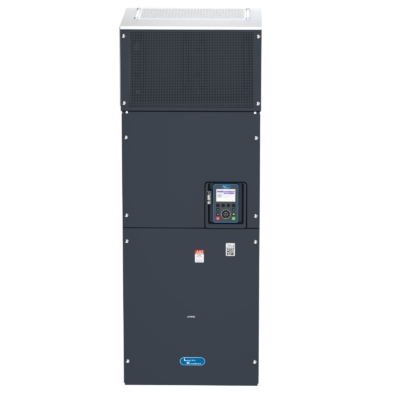
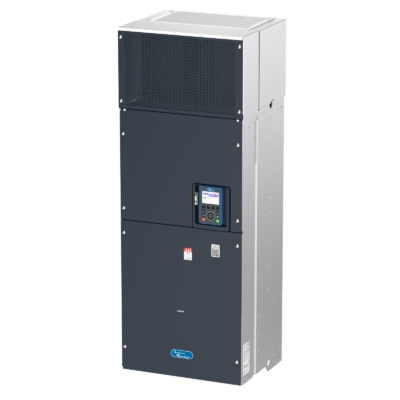
Lauritz Knudsen Electrical and Automation
XD4000 160kW(HD)/220kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
Lauritz Knudsen Electrical and Automation
XD4000 18.5kW(HD)/22kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
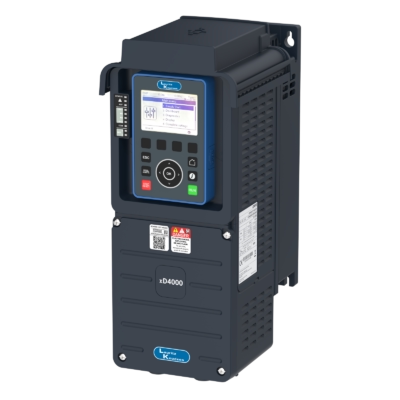
Lauritz Knudsen Electrical and Automation
XD4000 2.2kW(HD)/3kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
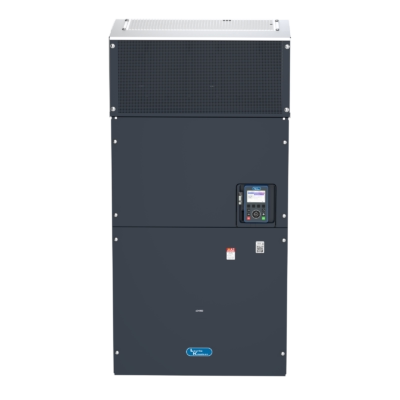
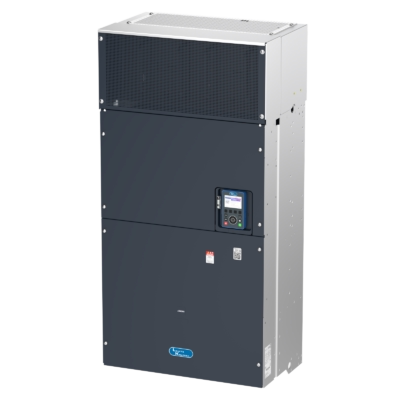
Lauritz Knudsen Electrical and Automation
XD4000 200kW(HD)/250kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
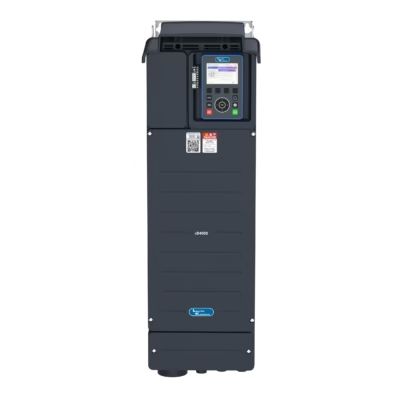
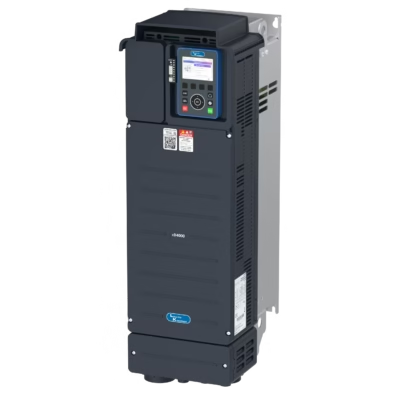
Lauritz Knudsen Electrical and Automation
XD4000 22kW(HD)/30kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
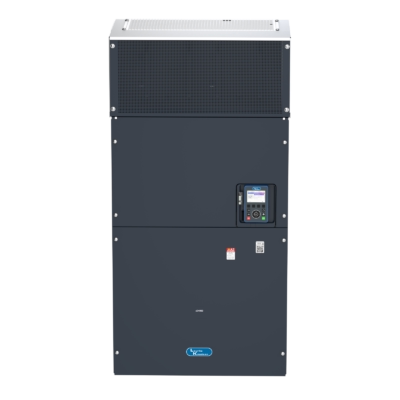
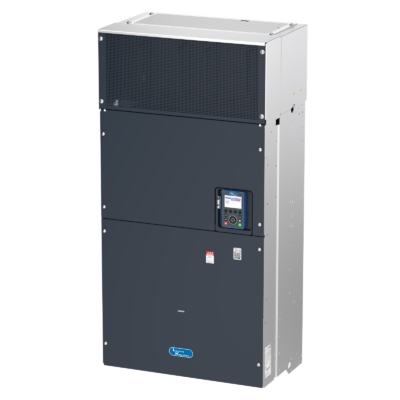
Lauritz Knudsen Electrical and Automation
XD4000 250kW(HD)/315kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
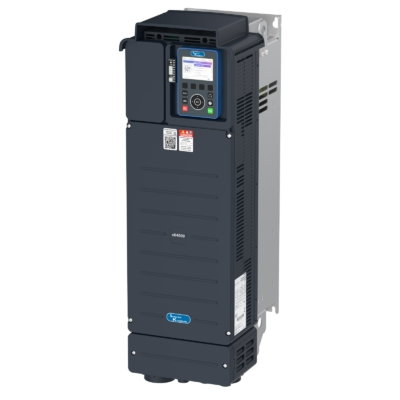
Lauritz Knudsen Electrical and Automation
XD4000 30kW(HD)/37kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
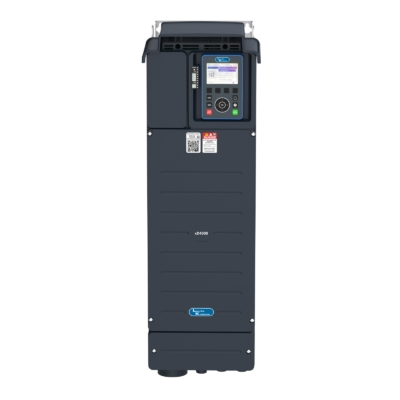
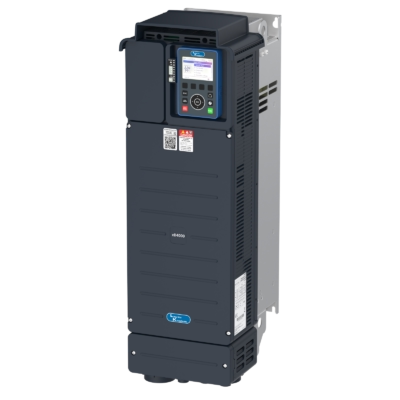
Lauritz Knudsen Electrical and Automation
XD4000 37kW(HD)/45kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
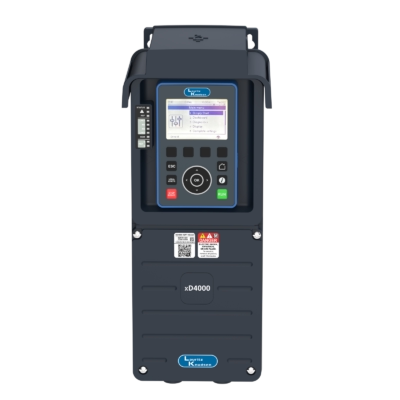
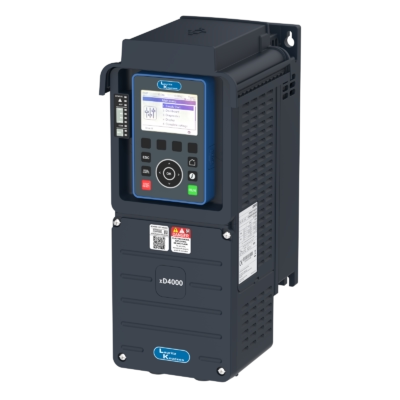
Lauritz Knudsen Electrical and Automation
XD4000 3kW(HD)/4kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
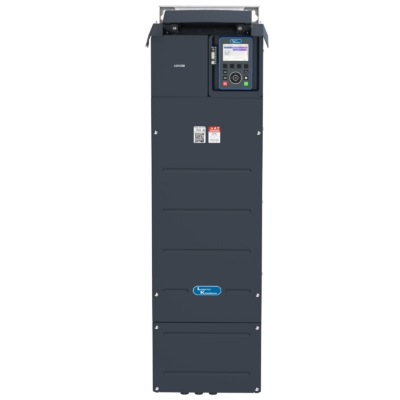
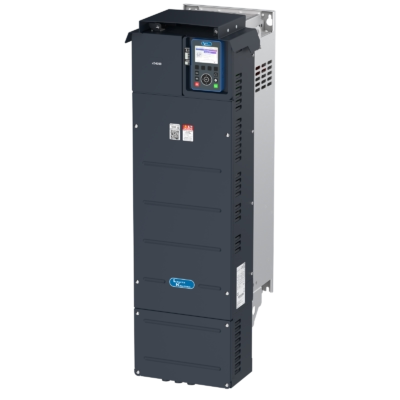
Lauritz Knudsen Electrical and Automation
XD4000 45kW(HD)/55kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
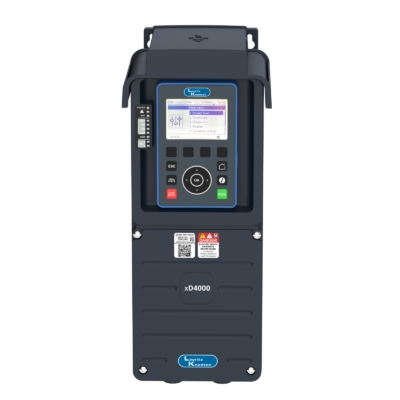
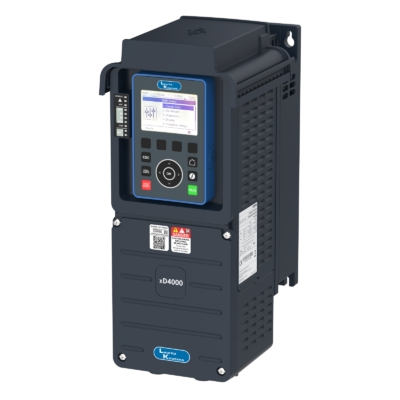
Lauritz Knudsen Electrical and Automation
XD4000 4kW(HD)/5.5kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
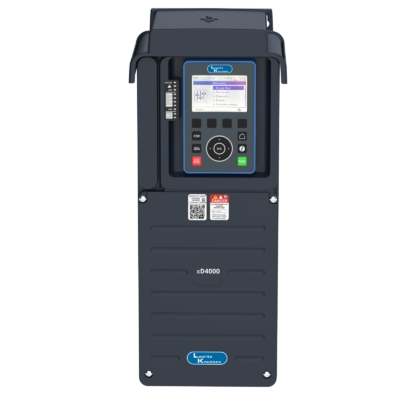
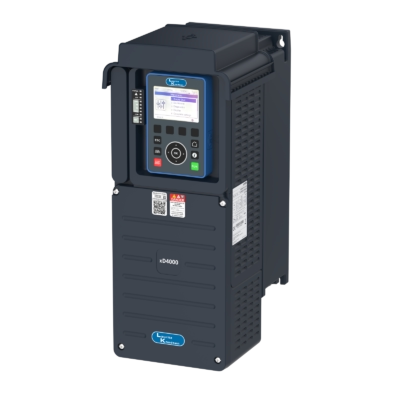
Lauritz Knudsen Electrical and Automation
XD4000 5.5kW(HD)/7.5kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
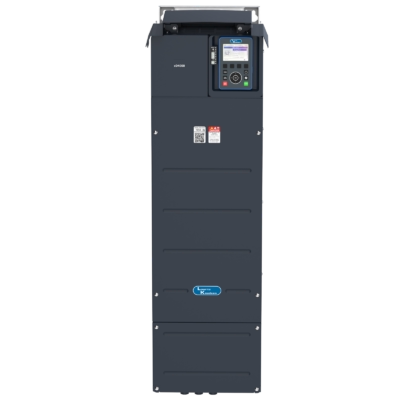
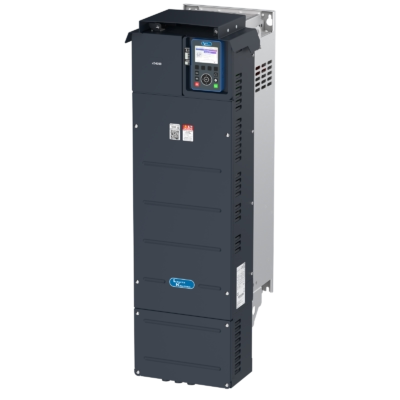
Lauritz Knudsen Electrical and Automation
XD4000 55kW(HD)/75kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
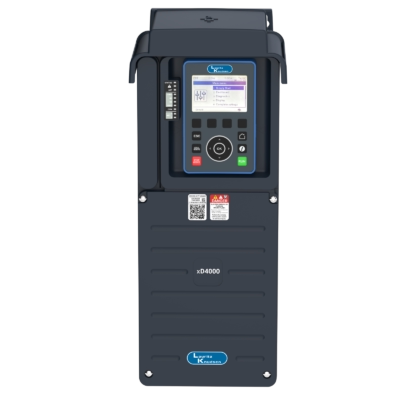
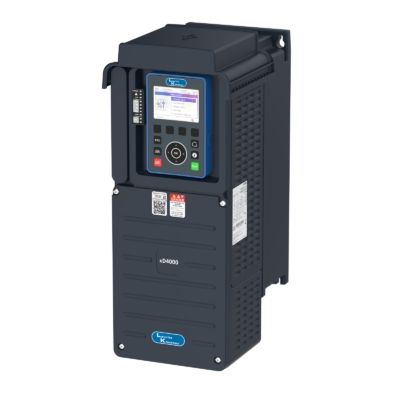
Lauritz Knudsen Electrical and Automation
XD4000 7.5kW(HD)/11kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
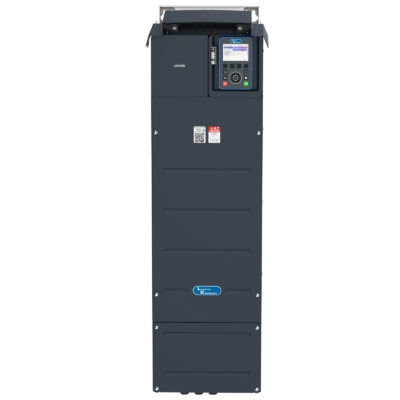
Lauritz Knudsen Electrical and Automation
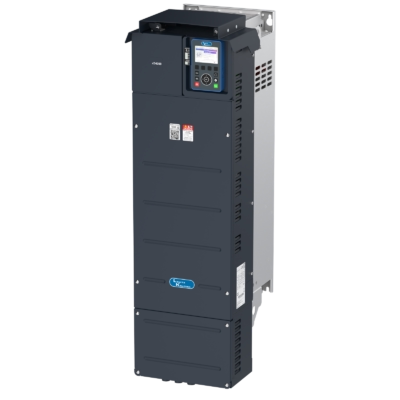
XD4000 75kW(HD)/90kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
Lauritz Knudsen Electrical and Automation
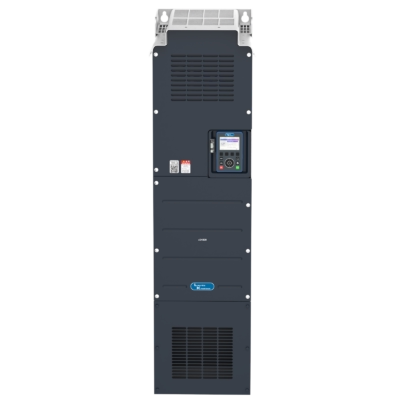
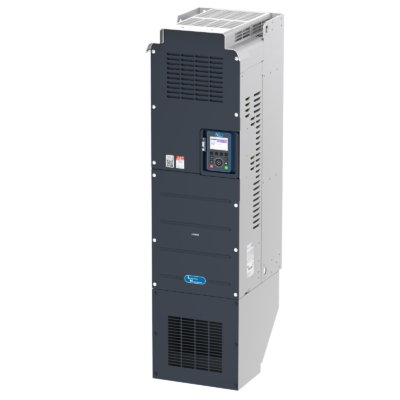
XD4000 90kW(HD)/110kW(ND) 415V Three-Phase Variable Frequency Drive | xD4000 Series VFD
